
Description
Math Foundations for Robotics: Vectors, Matrices, Calculus. This course is a specialized program that teaches the mathematical foundations of robotics, including vectors, matrices, calculus, and probability, along with full proofs and practical applications in robotics. This course is designed to serve as a standard bridge to bridge the gap between robotics courses and mathematics. Most robotics courses assume that students are already familiar with mathematics, while mathematics courses usually do not demonstrate the real-world application of formulas to robots. This course explores four key concepts in robotics, including vectors, matrices, calculus, and probability, and instead of blindly accepting formulas, it deduces and proves them all from the ground up. In this curriculum, no rule is presented without proof, and all concepts are derived from first principles. Each section includes a real-world robotics scenario that ultimately leads to a concrete application; From guiding a rover using vector sums to correcting the trajectory of a robotic arm in real time and tracking moving targets, the final part of the course combines all four ideas into a single control loop so that a robotic arm can track a moving object that can only be estimated. This course consists of 53 lessons and about nine hours of educational content with full source code, making it a good choice for a deep understanding of robotics engineering.
What you will learn
- Extracting the inner product from the law of cosines and using it to map one vector onto another vector
- Using external multiplication to calculate the torque acting on the robotic arm and understand the need for orientation in it
- Constructing rotation matrices from robot orientation and examining errors caused by their incorrect combination
- Chaining homogeneous transformations from camera viewpoint to robot global frame
- Analysis of eigenvectors and eigenvalues as directions that are not subject to rotation and their degree of elongation
- Calculating the Jacobian and relating the movement of individual joints to the movement of the robot arm simultaneously
- Running the gradient descent algorithm on a real target and investigating why the arm overpasses the target point before learning to stop
- Extracting Bayes’ rule and using it to update beliefs instead of replacing them completely
- Building a one-dimensional Kalman filter from scratch, including how to actually obtain the Kalman gain
- Combining all four ideas into a single control loop to capture a moving object that can only be estimated
This course is suitable for people who:
- Robotics students who can follow the code in simulation or Raw2 courses but struggle when math topics are introduced
- Self-taught engineers who need vectors, matrices, calculus, and probability applied to robotics without the need for a full math degree
- Anyone who has ever copied a Duran matrix or Kalman filter from a tutorial and now wants to understand why it works
- Developers moving from other software areas to robotics, machine vision, or control systems
- People looking for rigorous proofs of pure mathematics or quick cheat sheets of formulas (this course is not suitable for them)
Course Description Math Foundations for Robotics: Vectors Matrices Calculus
- Publisher: Udemy
- Instructor: Frank Robotics Lab
- Training level: Beginner to advanced
- Training duration: 9 hours and 11 minutes
- Number of lessons: 53
Course topics
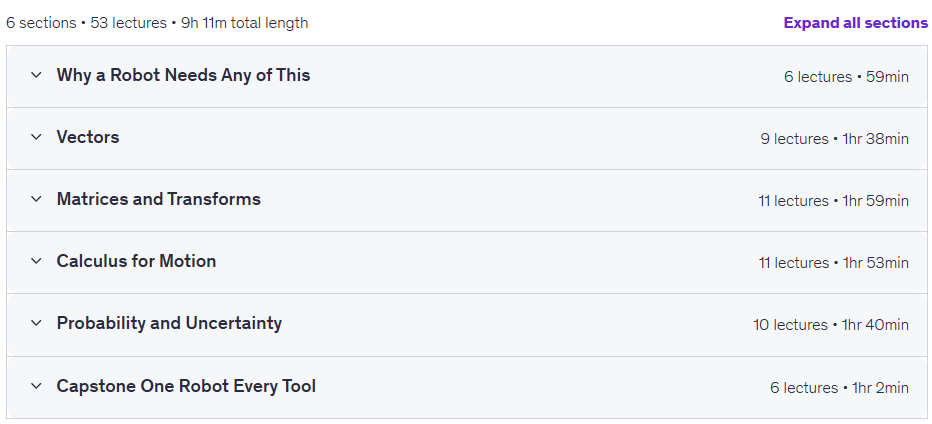
Prerequisites for the Math Foundations for Robotics: Vectors Matrices Calculus course
- Comfortable with high school algebra: rearranging an equation, reading a graph
- Able to read basic Python: variables, functions, a for loop. You don’t need to be a programmer
- No prior linear algebra, calculus or probability needed. Every idea is derived from the beginning
- Python 3 with numpy and sympy if you want to run the proof scripts yourself, which is encouraged but optional
Course images
Sample course video
Installation Guide
After Extract, view with your favorite player.
Subtitles: None
Quality: 1080p
Download link
Rapidgator link
File(s) password: www.downloadly.ir
File size
2.8 GB